How Does a Hoverboard Work? Step-by-Step
This post contains affiliate links. As an Amazon Associate, we earn from qualifying purchases.
A hoverboard works by using gyroscopes and accelerometers to measure the tilt of its foot platforms thousands of times per second. A central control board processes this data and adjusts the speed of two independent, brushless DC motors, one in each wheel, to counteract the tilt and keep the rider upright. Leaning forward tells the board to accelerate the motors; leaning back commands deceleration.
That’s the 30,000-foot view. The real magic is in the milliseconds. The system predicts and corrects dozens of times before you even feel a wobble, performing a high-speed balancing act on pavement.
What follows is a breakdown of the three systems that make it possible when you ask how does a hoverboard work: the sensors that feel your weight shift, the computer that makes the split-second decisions, and the motors that turn those decisions into motion. We’ll also cover why these wheeled scooters caused a fire scare, how they’re different from sci-fi levitating boards, and what you’re actually telling the machine to do when you lean.
Key Takeaways
- The gyroscope and accelerometer form an Inertial Measurement Unit (IMU) that detects tilt angle and rate of change hundreds of times per second.
- The control board uses a PID loop, a mathematical formula, to calculate the exact motor speed needed to correct your balance, preventing over-correction and wobbles.
- Two independent motors (often 250-350W each) allow for turning: slowing one wheel while speeding up the other creates a spin.
- UL 2272 certification is essential for safety; it’s a system-level standard created after reports of 52 fires in under three months led to a recall of over 500,000 units.
- You control speed by tilting the foot platforms, not steering. A forward tilt triggers acceleration; a rearward tilt commands braking, as explicitly stated in the Razor Hovertrax manual.
The Core Components: Sensors, Brains, and Power
Forget the plastic shell. Inside, a hoverboard is a compact robot built around a simple but urgent task: don’t let the human fall.
This technical overview covers the primary electromechanical systems of a standard self-balancing scooter. The system centers on an inertial measurement unit (IMU) containing a 3-axis gyroscope and a 3-axis accelerometer. This sensor data is processed by a main control board running a Proportional-Integral-Derivative (PID) algorithm, which outputs commands to two brushless DC motor controllers. The motors, integrated into the wheels, provide independent torque. Sources differ on typical battery voltage: the EVERCROSS EV2 uses a 24V pack, while a peer-reviewed technical paper and a reverse-engineering analysis describe 36V packs.
The Sensors: Feeling Every Micromovement
The system starts with its senses. Under each footpad is a pressure sensor, but the real heroes are the gyroscope and accelerometer, usually bundled into a single chip called an Inertial Measurement Unit (IMU).
The gyroscope measures rotational velocity, how quickly you’re tipping forward, backward, or side-to-side. The accelerometer measures linear acceleration, which helps determine the board’s tilt angle relative to gravity. Together, they report your orientation and movement hundreds of times per second. This feedback is a frantic, real-time data stream saying “we’re tipping, we’re tipping this fast, at this angle.”
Where this goes sideways: If these sensors get dirty, damaged, or misaligned, their data becomes garbage. The control board makes decisions based on faulty information, leading to the board jerking unexpectedly, refusing to balance, or driving itself in a circle. This is a common root cause for many repair issues owners face with their hoverboard.
The Control Board: The Split-Second Decision Maker
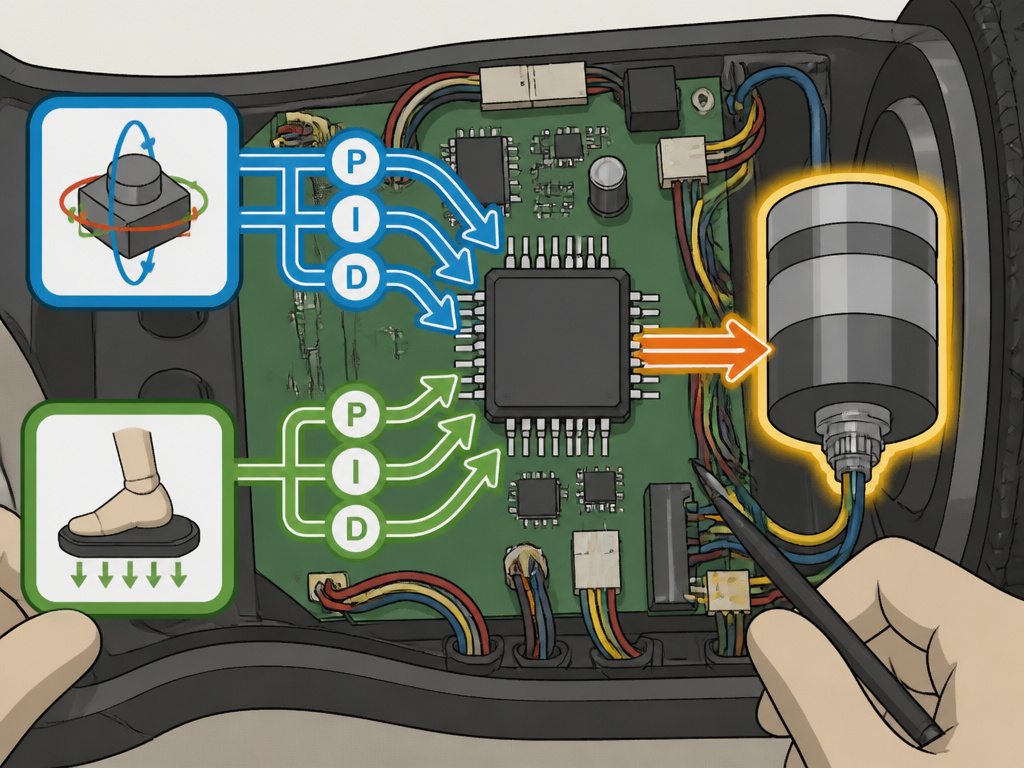
All that sensor data feeds into the brain: the main control board. This is where the complex math happens in real-time. The board runs a control algorithm, most commonly a Proportional-Integral-Derivative (PID) loop.
Think of the PID loop as the board’s instinct. The “P” (Proportional) term looks at how far you’re tilted right now and says “correct this much.” The “D” (Derivative) term looks at how fast you’re tilting and says “slow down that change to avoid overshooting.” The “I” (Integral) term looks at any persistent, uncorrected tilt and applies a steady correction to eliminate it. The result is a smooth, damped correction that feels natural, not robotic and jerky.
This process is continuous. You are never truly balanced on a static platform. You are perpetually being balanced by a computer making micro-adjustments. A study on repurposing hoverboards for robotics in the NIH PMC engineering analysis highlights this precise sensor fusion and PID control as the key to the platform’s stability.
The Power System: Battery and Motors
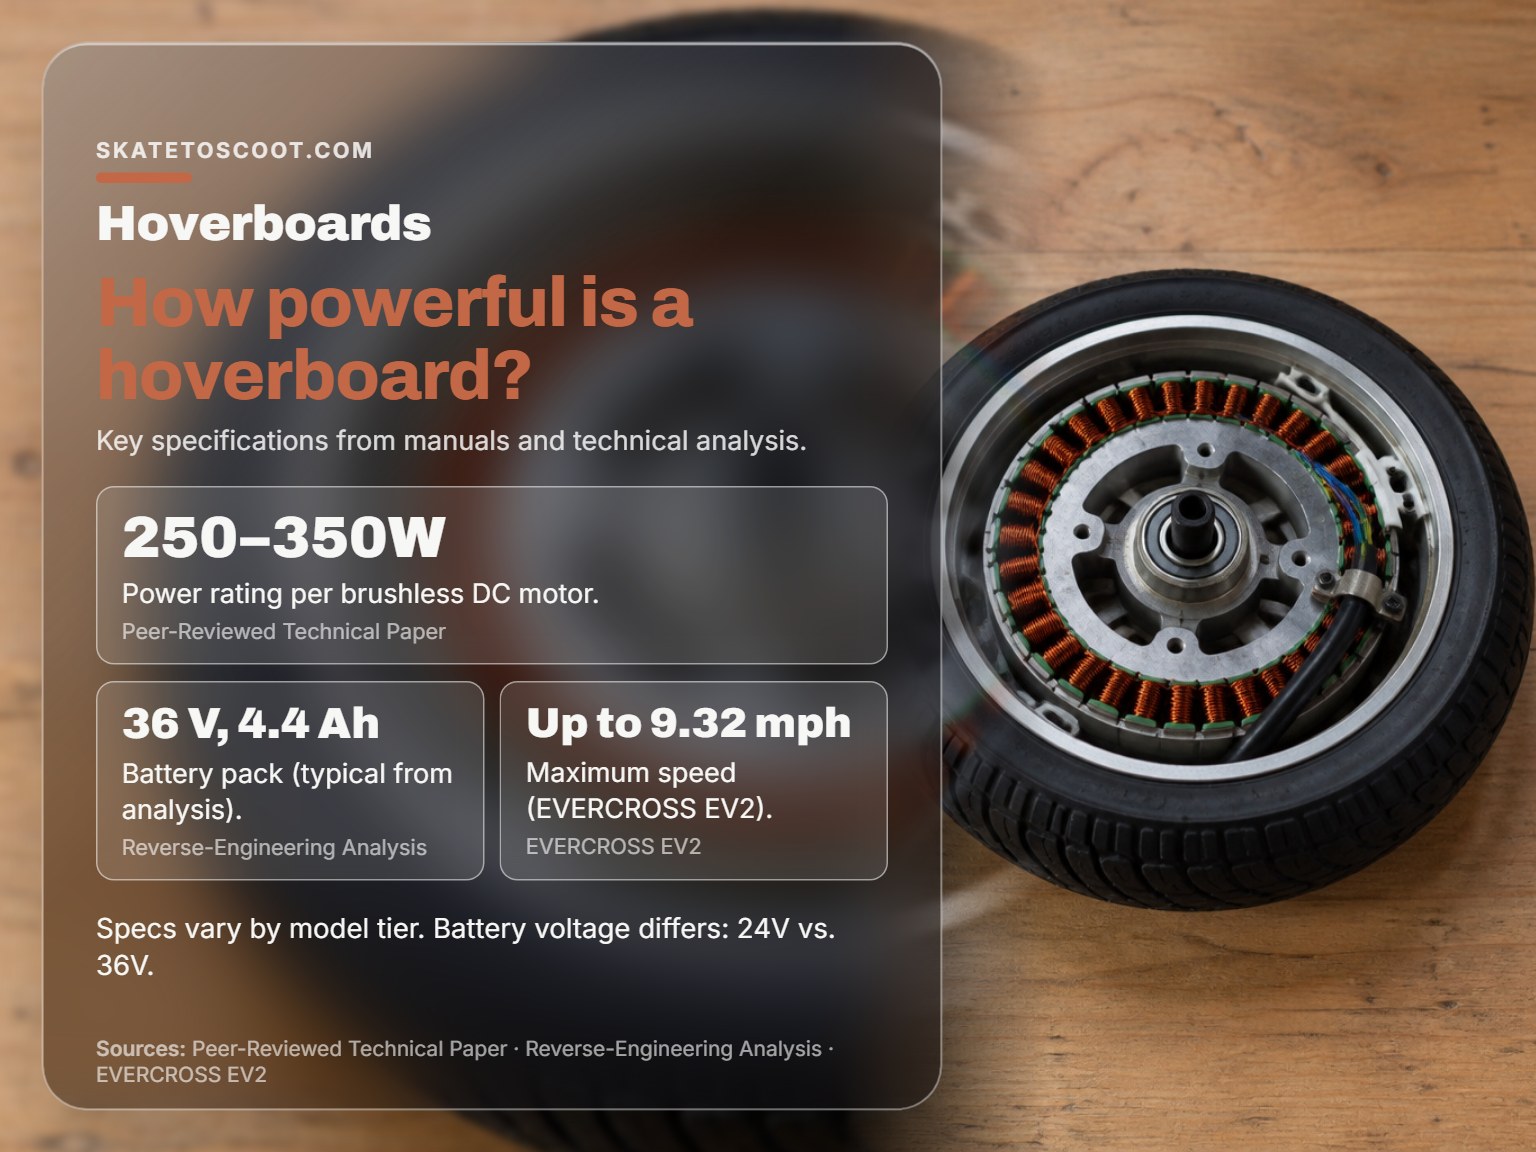
The control board’s commands are executed by the muscle: two brushless DC hub motors, one inside each wheel. A peer-reviewed technical paper cites typical motors rated between 250–350W each. They are powerful, quiet, and efficient.
These motors are independent. This independence is what allows for turning. To spin left, the board slows the left motor and speeds up the right motor. The degree of difference dictates how tight the turn is.
Powering it all is a lithium-ion battery pack. Here’s where sources show a key specification difference. The EVERCROSS EV2 manual lists a 24V, 4.0Ah battery, while a reverse-engineering analysis describes a 36V, 4.4Ah pack and a peer-reviewed technical paper cites a 36V lithium-ion battery pack. This isn’t a mistake, it reflects different product tiers and designs. The battery’s health is critical, not just for run-time but for safety, a lesson learned from the industry’s early days.
| Component | Primary Function | What Happens If It Fails |
|---|---|---|
| Gyroscope/Accelerometer (IMU) | Measures tilt angle and rotational speed. | Board cannot sense rider’s position, leading to immediate shutdown or erratic movement. |
| Main Control Board | Runs PID algorithm to calculate motor response. | Board may not power on, or motors may behave illogically (e.g., driving in opposite directions). |
| Brushless DC Motors | Provide torque to wheels based on control signals. | One wheel may not engage, making balance impossible, or motor may seize, throwing the rider. |
| Lithium-ion Battery Pack | Provides power to all systems. | Low capacity reduces ride time; damaged cells can overheat, posing a fire risk. |
How You Control It: Leaning Isn’t Steering
Most people think you steer a hoverboard. You don’t. You influence it. The board’s only goal is to keep its foot platforms level. You use that goal to your advantage.
The Razor Hovertrax manual states it clearly: “Movement, speed, and stopping are controlled by the degree to which the rider’s feet cause the foot platforms… To no longer be parallel to the ground.” It adds, “The device tries to re-level a forward tilt by accelerating, and tries to level a rearward tilt by decelerating.”
Lean forward. The sensors detect the front-down tilt. The PID loop on the control board calculates, “To re-level this, I need to drive the wheels forward.” The motors accelerate. You move forward, and the platform levels out beneath you. To stop, you lean back. The board sees a rear-down tilt and commands the motors to slow down or reverse until level again.
Turning is a clever hack on this system. To turn right, you press down with your right toe and/or lift your left heel. This creates a slight clockwise twist. The sensors detect this rotational tilt. The control board then commands the left motor to speed up and the right motor to slow down, spinning the board to the right.
Common mistake: Trying to steer with your upper body or knees. The board only reads pressure and tilt from your feet. If your feet aren’t directing the turn, the board won’t cooperate. This is the first hurdle in any guide to riding a hoverboard.
This is also why balance is everything. A nervous beginner often stands rigid, feet flat and parallel. The board reads this as “perfectly level, do nothing,” and it stays put. The first real step in learning to balance on a hoverboard is committing to that initial, tiny lean.
The Safety Evolution: From Fire Hazard to Certified Ride
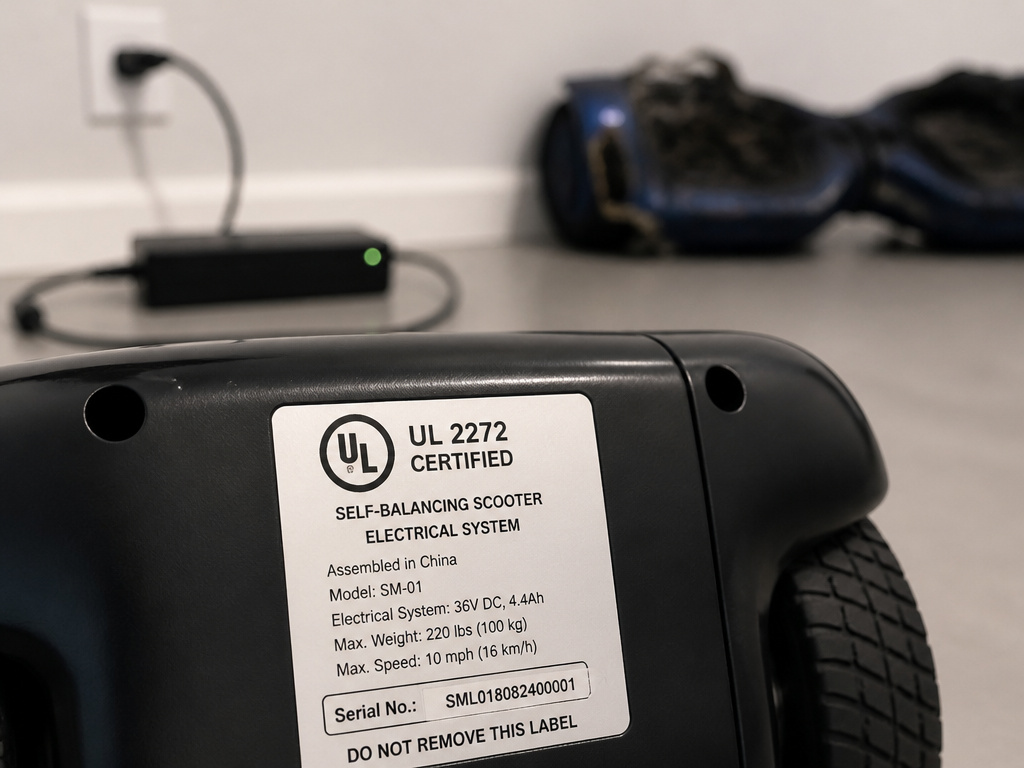
The hoverboard’s story is a case study in what happens when a hot new product hits the market without robust safety standards.
From December 1, 2015, to February 17, 2016, the U.S. Consumer Product Safety Commission (CPSC) received reports of 52 fires related to self-balancing scooters. The issue often stemmed from poorly manufactured battery packs and charging systems. On July 18, 2016, the CPSC announced a recall of over 500,000 hoverboards from 10 companies due to these fire hazards.
The response was the creation of UL 2272, the definitive safety standard. Unlike previous tests that looked at components in isolation, UL 2272 evaluates the entire electrical system as a whole, battery, charger, motors, and circuitry, under a range of conditions including overcharging, vibration, and temperature extremes. Today, you should never buy a hoverboard without this certification. It’s the difference between a toy and a tested vehicle.
This history explains the strict warnings in modern manuals. The EVERCROSS EV2 manual stresses regularly examining the charger for cord damage and notes its built-in overcharge protection. The reverse-engineering analysis warns that the “charger must be used unobstructed and well ventilated, and should never be covered.” A charger getting warm is normal; a charger buried under a blanket is a risk.
Real Hoverboards vs. Sci-Fi Levitation
The name causes endless confusion. When you search “how does a hoverboard work,” you’re as likely to find clips of magnetic levitation as you are of wheeled scooters.
A real hoverboard, as discussed here, is a self-balancing scooter. It’s a wheeled vehicle. It requires no special surface.
The levitating boards you see in viral videos, like the Lexus “Slide” or those using superconductors, are different beasts. They use the Meissner effect, where a supercooled superconductor repels a magnetic field, creating levitation. These boards require a continuous supply of liquid nitrogen to stay cold and must operate over a specially built magnetic track. They hover, but they are impractical for personal transport. They are brilliant physics demos, not commute tools.
This distinction matters because it sets realistic expectations for the how does a hoverboard work question. Your hoverboard won’t glide over water or grass. As the Razor manual bluntly puts it: “Only use… Indoors or on completely smooth surfaces.”
Performance and Limits: What the Specs Mean
Not all hoverboards are equal. The specs tell you what a specific model is built for.
Take the EVERCROSS EV2. Its manual lists a max speed of 9.32 mph (15 km/h), a max range of 6.2 miles (10 km), and a load capacity of 44-220 lbs (20-100 kg). It can handle a maximum incline angle of 15°. Compare this to the Razor Hovertrax Prizma/Lux, which has a lower max weight limit of 176 lb (80 kg) and recommends that children under the age of 8 not be permitted to use it.
Why the different weight limits? It comes down to motor power and battery capacity. A reverse-engineering analysis notes that generic boards with two 350W motors can typically transport riders up to 120 kg (260 lb). Exceeding the manufacturer’s limit doesn’t just drain the battery faster; it strains the motors and control system, leading to premature failure or a dangerous loss of power mid-ride.
| Specification | EVERCROSS EV2 | Razor Hovertrax Prizma/Lux | Generic Mid-Range Board (per analysis) |
|---|---|---|---|
| Max Weight | 220 lbs (100 kg) | 176 lbs (80 kg) | 260 lbs (120 kg) |
| Max Speed | 9.32 mph (15 km/h) | Not Specified | 8-10 mph (13-16 km/h) |
| Motor Power | Not Specified | Not Specified | Typically 2 x 350W (per analysis) |
| Best For | Teens & Adults | Older Children & Light Adults | General Use |
Speed is often governed. The EVERCROSS EV2 will alarm if speed exceeds 12 km/h, and many have a beginner mode that caps speed lower. This is a crucial safety feature, especially when learning the unique speed dynamics of a hoverboard.
Why Balance Fails and How to Fix It
Even with perfect tech, things go wrong. The most common complaint is an off-balance hoverboard, one that drifts to one side, lists forward, or won’t stay level when started.
Usually, this is a calibration issue. The board needs to relearn what “level” is. The process typically involves placing the board on a perfectly flat surface, pressing a button, and waiting for lights to flash. If calibration doesn’t work, the problem may be a faulty pressure sensor under a footpad, a dying motor, or, most seriously, a failing IMU sensor cluster.
The part nobody mentions: An unbalanced board often feels “twitchy” or “drunk” before it completely fails. It might over-correct small leans or vibrate underfoot. That’s your warning sign. Don’t ignore it.
Fixing it starts with the basic calibration process for a hoverboard. If that fails, you’re looking at component-level diagnosis. This is where understanding the core components pays off. Knowing the difference between a motor hum and a motor grind, or recognizing that a persistent drift points to a sensor issue, can save you time and money.
How to ride a hoverboard for the first time
Start by placing the hoverboard on a flat, smooth surface indoors. Turn it on and wait for it to level itself. To mount, hold onto a stable support like a wall or chair, place one foot firmly on a footpad, and then quickly bring your other foot up. Stand upright with your feet shoulder-width apart. The device balances you forward and back, but you must control side-to-side stability. To move forward, gently press your toes down. To slow down or go backward, press your heels. To turn, apply more pressure with one foot than the other. Always step off backward, leading with one foot, and never jump off. Practice these movements slowly in a safe, open area.
Frequently Asked Questions
How does a hoverboard know where to go?
It doesn’t. A hoverboard has no GPS or navigation sense. It only knows one command: keep the foot platforms level with the ground. You provide the “where” by manipulating that level state through your weight. Your lean dictates the direction and speed as the board constantly works to correct back to neutral.
How do you control hoverboards?
You control them exclusively through foot pressure and tilt. Shift your weight forward to go forward, backward to brake or reverse. To turn, apply more pressure to one foot (e.g., press right toe to turn right). The board translates these pressure changes into motor commands. Upper body movement does nothing unless it changes the pressure under your feet.
Why did hoverboards get banned?
They were banned from airlines, universities, and public transit in 2015-2016 due to fire risks from uncertified lithium-ion batteries. The U.S. CPSC recall of over 500,000 units and the creation of the UL 2272 safety standard directly addressed these hazards. Today, UL 2272-certified boards are widely accepted, though some transit bans may still remain.
What age should a kid get a hoverboard?
Manufacturer recommendations vary. Razor recommends its Hovertrax Prizma/Lux for riders 8 years and older, citing not just weight but maturity and skill. The EVERCROSS EV2 supports riders from 44 lbs, but adult supervision is always crucial. The decision should be based less on a specific age and more on the child’s coordination, ability to follow safety rules, and comfort wearing full protective gear.
How long does it take to charge a hoverboard?
Charging time depends on battery capacity. Always follow the specific charging guidelines in your manual. The EVERCROSS EV2 manual provides a clear indicator: a solid green light means the battery is between 15-100%, and a flashing red light means it’s between 5-15% and needs charging. Always follow the specific charging duration guidelines in your manual and never leave it charging unattended overnight.
The Bottom Line
A hoverboard is a masterpiece of consumer robotics hiding in plain sight. It’s not magic; it’s milliseconds. Gyroscopes sense a tilt, a PID loop on a control board calculates the counter-move, and motors execute it, all before your brain registers the stumble.
That engineering marvel comes with real responsibilities. The UL 2272 certification is your first and most important filter. It’s the hard-won answer to a dangerous chapter in this product’s history. Pair that with a clear understanding of the limits in your manual, the weight cap, the terrain warnings, the charging rules.
Finally, adjust your expectations. You’re not steering a scooter. You’re collaborating with a balancing robot. Your job is to commit to the lean and trust the machine’s relentless corrections. Master that partnership, and the ride clicks into place. Ignore the specs or the safety certs, and you’re asking for a short, frustrating experience.
